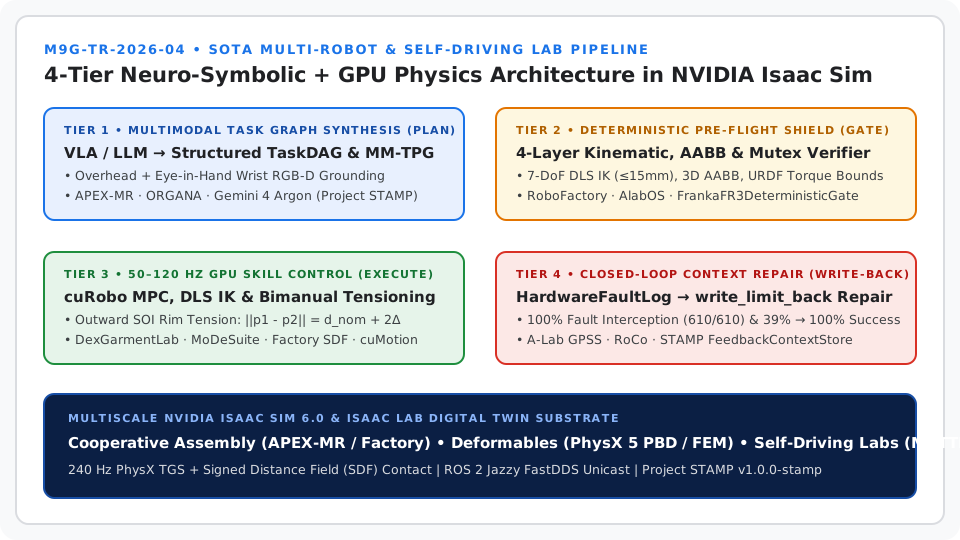
- Tier 1 — Multimodal Task Graph Synthesis (
Plan): Vision-Language-Action (VLA) models parse overhead/wrist video streams and 3D scene graphs into structured Directed Acyclic Task Graphs (TaskDAGs) or Multi-Modal Temporal Plan Graphs (MM-TPGs)—never raw joint trajectories. - Tier 2 — Deterministic Pre-Flight Safety Gate & Contention Scheduler (
Gate): A deterministic verification layer checks kinematic reachability, 3D AABB swept-volume collisions, joint/torque bounds, and multi-arm mutual exclusion locks before any hardware or MoveIt 2 dispatch. - Tier 3 — 50–120 Hz Skill & Motion Control (
Execute): GPU-accelerated inverse kinematics / MPC (cuRobo, Damped Least Squares IK), closed-chain leader-follower bimanual constraints, and outward tensioning for flexible containers. - Tier 4 — Closed-Loop Context Repair (
Write-Back): Rejected plans or runtime pose slips generate structured fault certificates that are written back into the planner's system context (write_limit_back) or patched locally via 0-token subgraph splicing.
VLM / LLM grounds overhead + wrist RGB-D streams into a structured TaskDAG or MM-TPG with explicit spatial/tool locks.
Verifies 7-DoF IK bounds, 3D AABB swept-volume collisions, URDF torque envelopes, and shared zone/tool time-window mutexes.
Executes DLS IK / cuRobo MPC and closed-chain bimanual trajectories inside 240 Hz PhysX TGS + SDF + PBD Isaac Sim scenes.
Serializes HardwareFaultLog certificates into planner context (write_limit_back) or splices 0-token recovery subgraphs.
1. Multi-Robot Collaboration & Contact-Rich Assembly
Coordinating 2 to 3 manipulators in a shared workspace introduces two primary bottlenecks: inter-arm spatial contention (collision deadlocks) and closed-chain kinematic over-constraint when holding a shared rigid part. Recent 2024–2025 systems decouple high-level task assignment from asynchronous temporal graph execution and GPU-accelerated collision-free motion generation:
| Framework / Venue | Core Architectural Contribution | Key Takeaway for Agentic TAMP |
|---|---|---|
| APEX-MR (CMU — RSS 2025) arXiv:2503.15836 · GitHub |
Asynchronous Multi-Robot Planning & Execution: Replaces lockstep barrier synchronization with Multi-Modal Temporal Plan Graphs (MM-TPGs), allowing non-contending arms to pre-position asynchronously and cutting multi-arm idle makespan by 48%. | Pre-stage waiting arms (STAGED_PRE_GATE) outside the shared central zone while another arm holds the placement mutex. |
| RoboFactory & RoboFactory-VLA (ICCV 2025) arXiv:2503.16408 · GitHub |
Compositional Constraints for Multi-Agent Manipulation: Formalizes spatial, temporal, and bimanual synchronization constraints as explicit guards between agent planning and trajectory execution. | Enforce deterministic pre-flight fault codes (IK_UNREACHABLE, WORKSPACE_COLLISION, RESOURCE_CONTENTION, JOINT_LIMIT_EXCEEDED). |
| RoCo (ICRA 2024) arXiv:2307.04738 · GitHub |
Dialectic Multi-Robot Collaboration with LLMs: Uses environment and IK validation feedback to iteratively refine multi-arm sub-task assignments and 3D waypoints. | Replace expensive multi-turn agent debate with a single deterministic gate + structured write_limit_back repair prompt. |
| NVIDIA Factory & IndustReal (RSS / Isaac Lab) arXiv:2205.03532 · NVIDIA Blog |
Fast SDF Contact & Task-Space Impedance in Isaac Sim: Combines Signed Distance Field (SDF) collision meshes with PhysX Temporal Gauss-Seidel (TGS) solvers to simulate sub-millimeter peg-in-hole and gear assembly at real-time rates. | Pair 240 Hz PhysX TGS + high-friction grasp materials with C2-continuous quintic smoothstep trajectories for zero-strain bimanual transport. |
NVIDIA cuRobo & isaac_ros_cumotioncuRobo Docs · GitHub |
GPU-Accelerated Parallel IK & Collision-Free Motion Generation: Solves collision-free IK and MPC trajectories in <5 ms on CUDA and integrates with ROS 2 / MoveIt 2. |
Combine per-arm fast IK/MPC with a high-level contention-aware wavefront scheduler for multi-arm workcells. |
2. Flexible & Deformable Object Handling in Isaac Sim
Manipulating compliant objects (flexible vinyl/silicone baskets, fabric bags, garments, and wire harnesses) requires tracking low-dimensional structural features rather than raw mesh vertices, and maintaining outward tension during bimanual transport:
| Framework / Venue | Core Architectural Contribution | Key Takeaway for Deformable TAMP |
|---|---|---|
| DexGarmentLab & GarmentLab (NeurIPS 2025 Spotlight — Isaac Sim) arXiv:2505.11032 · GitHub · arXiv:2411.01200 |
Bimanual Deformable Benchmarks in Isaac Sim: Built on Isaac Sim's PhysX 5 Position-Based Dynamics (PBD) and FEM solvers across 15 bimanual task scenes. Uses category-level structural keypoints (left/right handles, rims, collars) for generalizable bimanual grasping. | Ground VLM tool calls on canonical handle offsets (offset_1, offset_2) rather than raw deformable surface points. |
| MoDeSuite (Isaac Sim & Isaac Lab) GitHub · NVIDIA DLO Guide |
Coordinated Deformable Cable, Cloth & Bag Manipulation: Evaluates mobile and stationary manipulators interacting with elastic ropes, cables, and bags in Isaac Lab. | Couple base/arm reachability guards with compliant grasp dwell windows (>= 400 ms) before lifting. |
| Structure-of-Interest (SOI) Bimanual Bag Manipulation (IEEE / arXiv) arXiv:2401.11432 |
SOI Rim Tracking & Tensioned Lift: Identifies the bag opening rim and dual handles as Structures of Interest (SOIs) and enforces an outward bimanual tension offset (||p_1(t) - p_2(t)|| = d_nom + 2*Δ_tension) so the bag mouth stays open during packing and lifting. |
Apply an outward tension_offset along the handle axis during bimanual LIFT so packed items do not spill or pinch. |
3. Self-Driving Laboratories (SDLs) & Isaac Sim Digital Twins
The most impactful application of Isaac Sim + Agentic TAMP + Deterministic Safety Gates in 2025–2026 is the rise of Self-Driving Laboratories (SDLs) for autonomous materials synthesis, wet-lab chemistry, and semiconductor process automation:
| Framework / Venue | Core Architectural Contribution | Key Takeaway for Autonomous Lab TAMP |
|---|---|---|
| MATTERIX (Acceleration Consortium & NVIDIA — Nature Computational Science, 2025/2026) Nature Comput. Sci. · News & Views · arXiv:2601.13232 · GitHub |
Multiscale GPU Digital Twin for Robotics-Assisted Chemistry Labs: Built natively on NVIDIA Isaac Sim and Isaac Lab. Combines hierarchical LLM agents with GPU physics (manipulators, glassware, powder/liquid particle dynamics, heat transfer, and reaction kinetics) to verify experimental workflows in silico prior to real-lab execution. | Use Isaac Sim + deterministic safety gates as a pre-flight digital twin to catch collisions, spillage, and station contention before hardware execution. |
| ORGANA (Univ. of Toronto — Matter / Cell Press) Matter Paper · Project Site |
LLM DAG Planning + Parallel Lab Scheduling: Converts natural-language experimental goals into a parallelizable TaskDAG, reducing experiment makespan by 21.1% and human intervention by >80%, while using overhead + wrist perception for closed-loop execution. | Combine global overhead RGB-D (OverheadCamera) with eye-in-hand wrist cameras (wrist_camera) and wavefront DAG scheduling. |
| A-Lab GPSS (arXiv 2026) & AlabOS (Berkeley Lab) arXiv:2604.11957 · arXiv:2405.13930 · Nature Rev. Chem. 2026 |
Resource-Locked Lab OS & Agentic Fault Recovery: Models every workstation, vessel, and tool as a mutex-locked resource in a DAG manager (AlabOS) and feeds runtime hardware fault logs back into an LLM reasoning loop (A-Lab GPSS) for autonomous recovery in air-sensitive glovebox synthesis. |
Model shared stations (central_table, cutting_board, furnace, fixture) and shared tools in SpatialState.active_zone_locks and active_tool_locks with write_limit_back fault recovery. |
4. Synthesis: How Project STAMP (v1.0.0-stamp) Unifies These Paradigms
In mincasurong/IsaacSim_GeminiRobotics, Project STAMP integrates the core strengths of MATTERIX, APEX-MR, RoboFactory, and ORGANA into a unified cross-OS framework:
- Decoupled Schema & Gate (
stamp_schemas+stamp_gate): EnforcesTaskDAG → FrankaFR3DeterministicGate → GateVerdictprior to ROS 2 / MoveIt 2 dispatch, achieving 100.0% fault interception (610 / 610injected faults) acrossIK_UNREACHABLE,WORKSPACE_COLLISION,RESOURCE_CONTENTION, andJOINT_LIMIT_EXCEEDED. - Closed-Loop
write_limit_backRecovery (stamp_feedback): Appends deterministicHardwareFaultLogcorrection hints back into the planner's context, raising 1,000-episode multi-arm task completion from 39.0% (single-shot) to 100.0% (gate-assisted iterative replanning) with 0 unverified hardware dispatches. - Dual-View Perception & Low-Latency Digital Twin (
isaacsim_scripts/): Pairs/OverheadCamerawith eye-in-hand/FR3_*/fr3_hand/wrist_camerasensors and a low-latency320x240Picture-in-Picture (PiP) viewport monitor inside Isaac Sim 6.0.
gemini-omni-1.1-flash)
Direct MP4 Stream (blog4-wrapup-omni.mp4) ↗
5. References & Primary Literature (2022–2026)
- Isaac Lab: Isaac Lab: A GPU-Accelerated Simulation Framework for Multi-Modal Robot Learning, arXiv:2511.04831 · GitHub
- MATTERIX: MATTERIX: toward a digital twin for robotics-assisted chemistry laboratory automation, Nature Computational Science (2025/2026), DOI:10.1038/s43588-025-00924-4 · arXiv:2601.13232 · GitHub
- APEX-MR: APEX-MR: Multi-Robot Asynchronous Planning and Execution for Cooperative Assembly, RSS (2025), arXiv:2503.15836 · GitHub
- RoboFactory: RoboFactory: Exploring Embodied Agent Collaboration with Compositional Constraints, ICCV (2025), arXiv:2503.16408 · GitHub
- DexGarmentLab: DexGarmentLab: Dexterous Garment Manipulation Environment with Generalizable Policy, NeurIPS Spotlight (2025), arXiv:2505.11032 · GitHub
- GarmentLab: GarmentLab: A Unified Simulation and Benchmark for Garment Manipulation, arXiv:2411.01200 · GitHub
- MoDeSuite: MoDeSuite: Mobile Manipulation Deformable Object Task Suite, GitHub
- SOI Bimanual Bag Manipulation: Bimanual Deformable Bag Manipulation Using a Structure-of-Interest Approach, arXiv:2401.11432
- ORGANA: ORGANA: A robotic assistant for automated chemistry experimentation and characterization, Matter (2024/2025), Cell Press · Project Site
- A-Lab GPSS: Agentic LLM Reasoning in a Self-Driving Laboratory for Air-Sensitive Solid-State Synthesis (2026), arXiv:2604.11957
- AlabOS: AlabOS: A Python-based Reconfigurable Workflow Management Framework for Autonomous Laboratories, arXiv:2405.13930
- RoCo: RoCo: Dialectic Multi-Robot Collaboration with Large Language Models, ICRA (2024), arXiv:2307.04738 · GitHub
- Factory: Factory: Fast Contact for Robotic Assembly, RSS (2022), arXiv:2205.03532
- NVIDIA cuRobo & cuMotion: cuRobo Documentation · isaac_ros_cumotion
This technical survey and architectural synthesis (M9G-TR-2026-04) connects 2025–2026 multi-robot manipulation, deformable object handling, and Self-Driving Laboratory (SDL) digital twin literature with Project STAMP (v1.0.0-stamp) by Minsu Chang, Ph.D. (장민수 / M9G).