M9G Technical Research & Engineering Blog
Concise engineering disclosures on multi-robot VLA manipulation in NVIDIA Isaac Sim 6.0 & ROS 2, deterministic robot safety gates, and multi-agent coding harnesses.
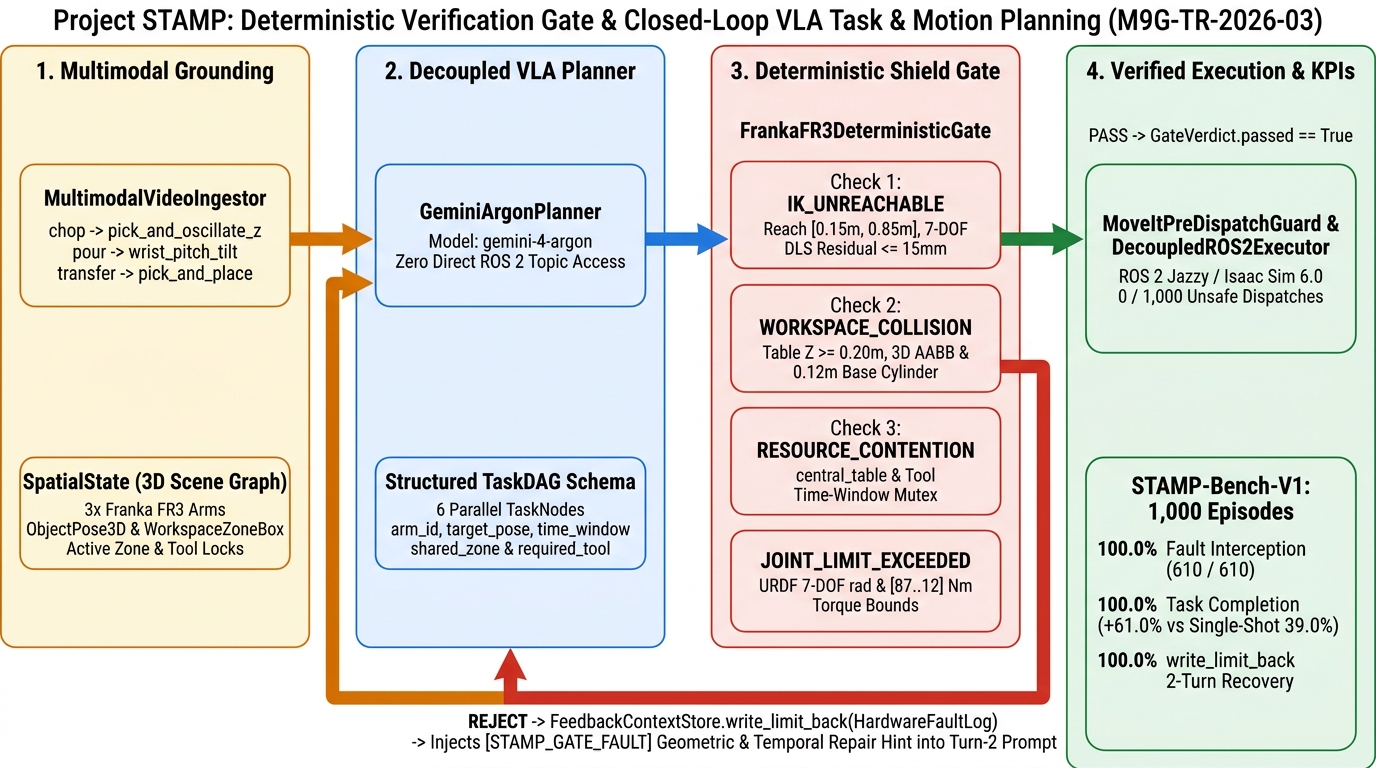 Blog 03 • STAMP
Project STAMP: Deterministic Verification Gates & Closed-Loop Context Repair for Multi-Arm VLA Planning
4-stage Plan → Gate → Execute → Write-Back pipeline blocking 610/610 physical IK, collision, torque, and zone-lock faults and raising task completion from 39% to 100%.
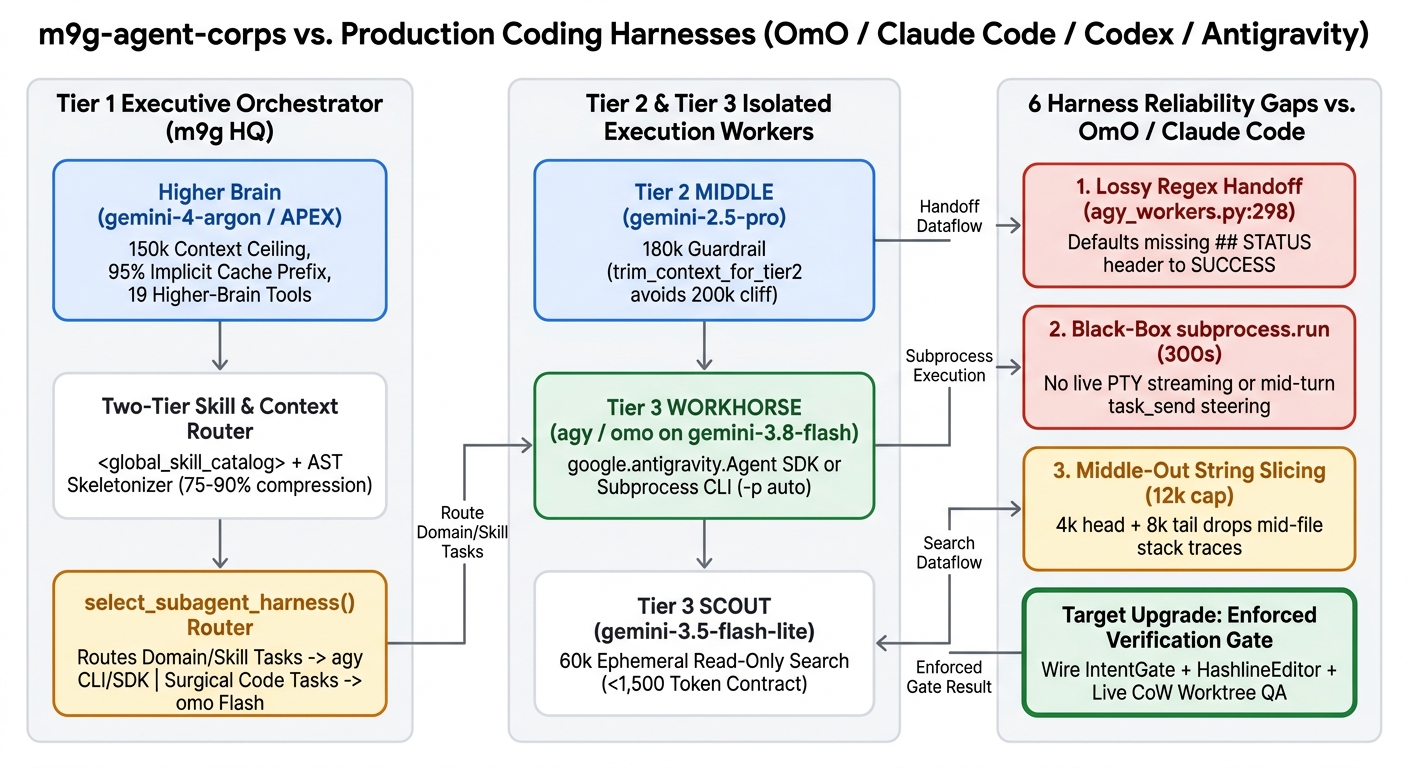 Blog 02 • Agents
Building a Multi-Agent Coding Harness from Scratch and Why It Failed: Inside m9g-agent-corps vs. OmO, OpenCode & Claude Code
Why our 28-module, 169-test standalone harness lagged pre-existing harnesses across 6 root failure modes—and how we extracted its best substrates into the m9g-mcp server.
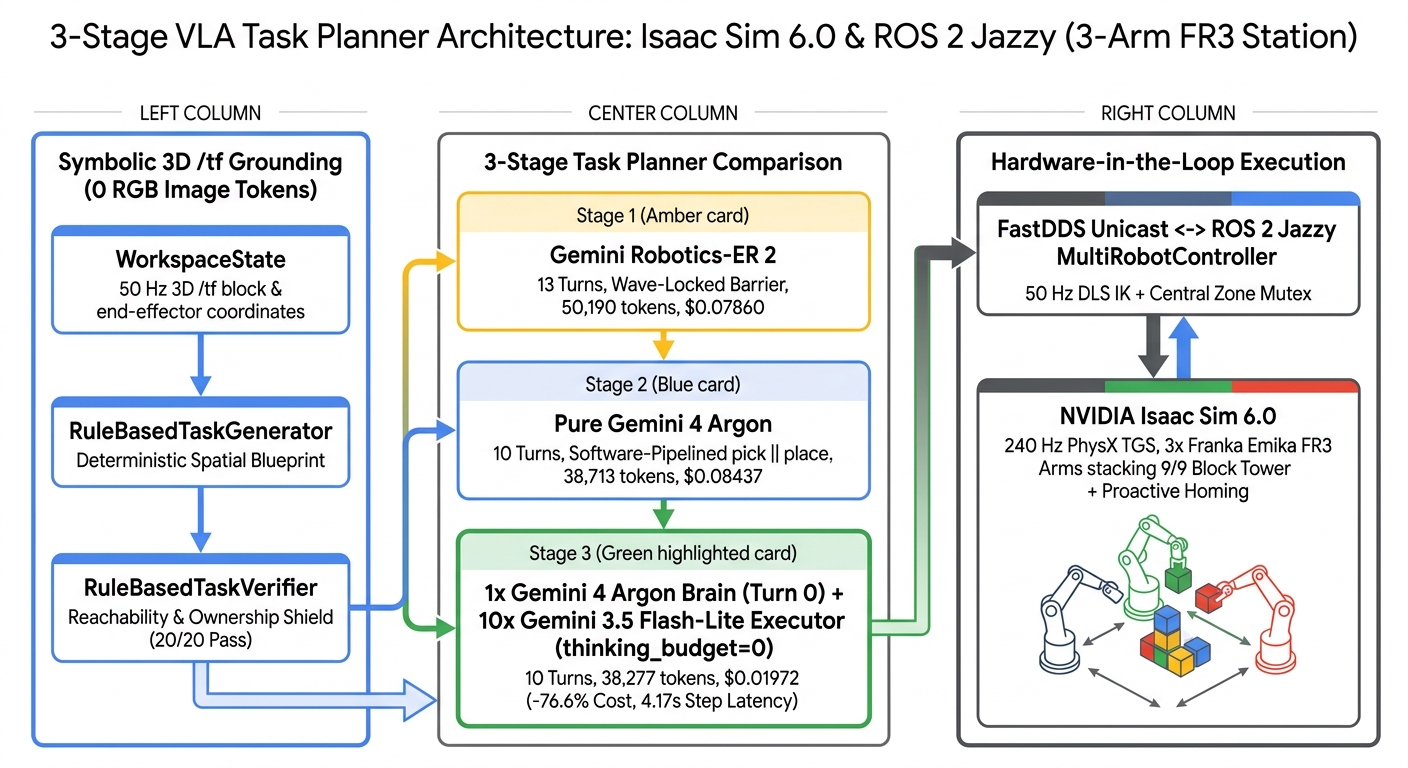 Blog 01 • VLA
Symbolic 3D Grounding and Software-Pipelined VLA Task Planning: Gemini Robotics-ER 2 vs. Gemini 4 Argon
3-stage hardware-in-the-loop benchmark in Isaac Sim 6.0 & ROS 2 Jazzy achieving a 10-turn pipelined schedule with 0 RGB image tokens and -68.7% step latency.